View full engineering process (PDF)
01 What
Built a robot to retrieve and carry payloads across a defined course for Warman Challenge Australia, as part of Mechatronics Design Fundamentals. As team lead I split the workload, designed the mechanism in SolidWorks, wired the electronics and wrote the C++ code, taking ownership of the robot from CAD to competition.
02 How
- 01Designed the vertical and horizontal actuation mechanism in SolidWorks, with a gripper on a mecanum drive base.
- 02Wired the electronics and wrote the C++ code: an Arduino and L298N motor driver boards on low voltage DC, with spindle motors for accurate telescopic actuation and DC motors for the mecanum drive.
- 033D printed the actuation mechanism and developed it through five CAD revisions (REV A to E), guided by what testing showed.
- 04Wrote the engineering documentation for the height variation mechanism: a decision matrix, lead screw and power calculations, and a full drawing pack.
03 Result
- -The robot met its design requirements: precise, fast and actuated by a single switch.
- -Mechanics, electronics and code working together in one machine.
- -The engineering documentation, including reporting, scored 100% in Mechatronics Design Fundamentals.
More Engineering Projects
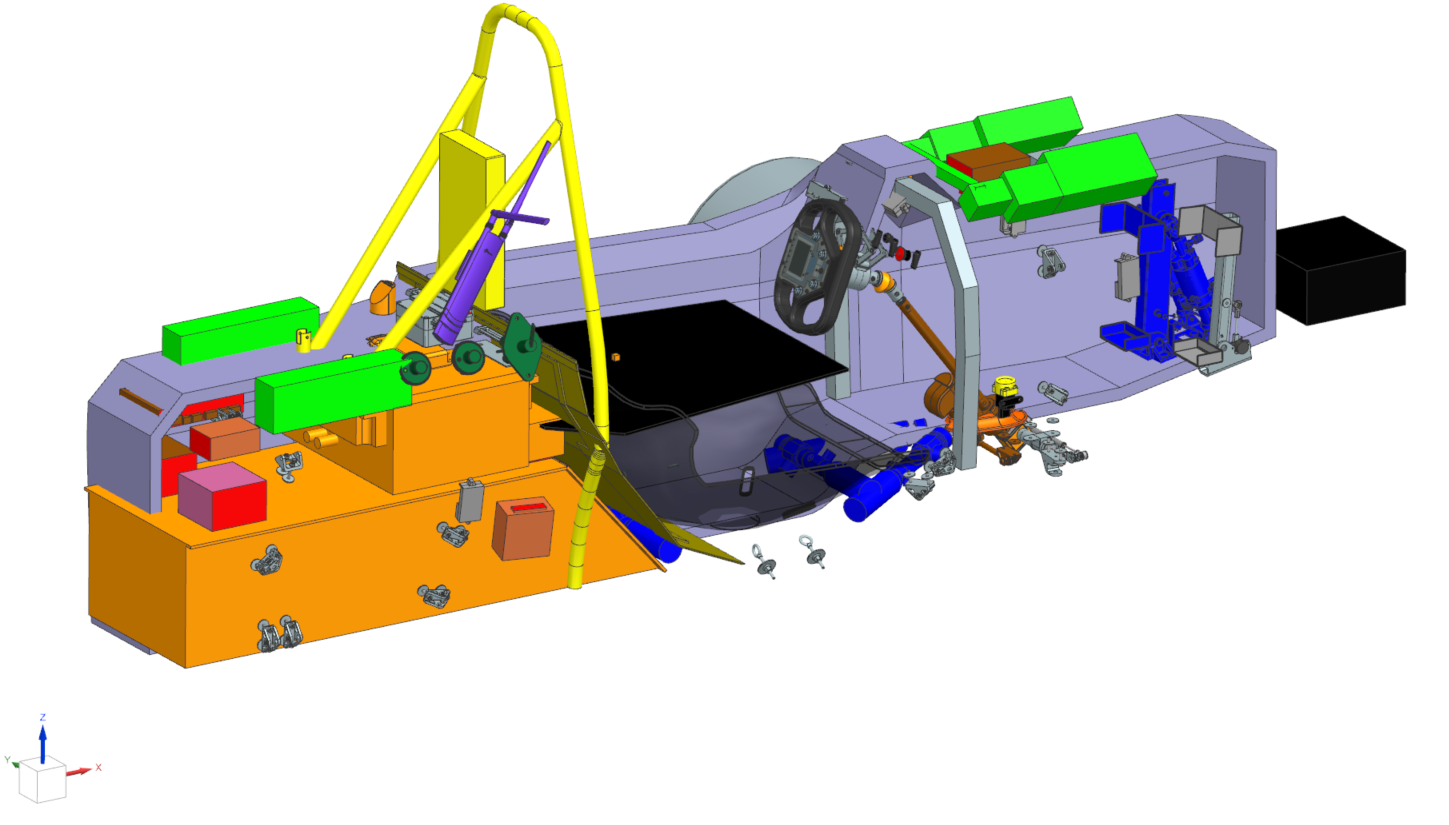
CAD & Packaging
CAD Monocoque Design & Packaging
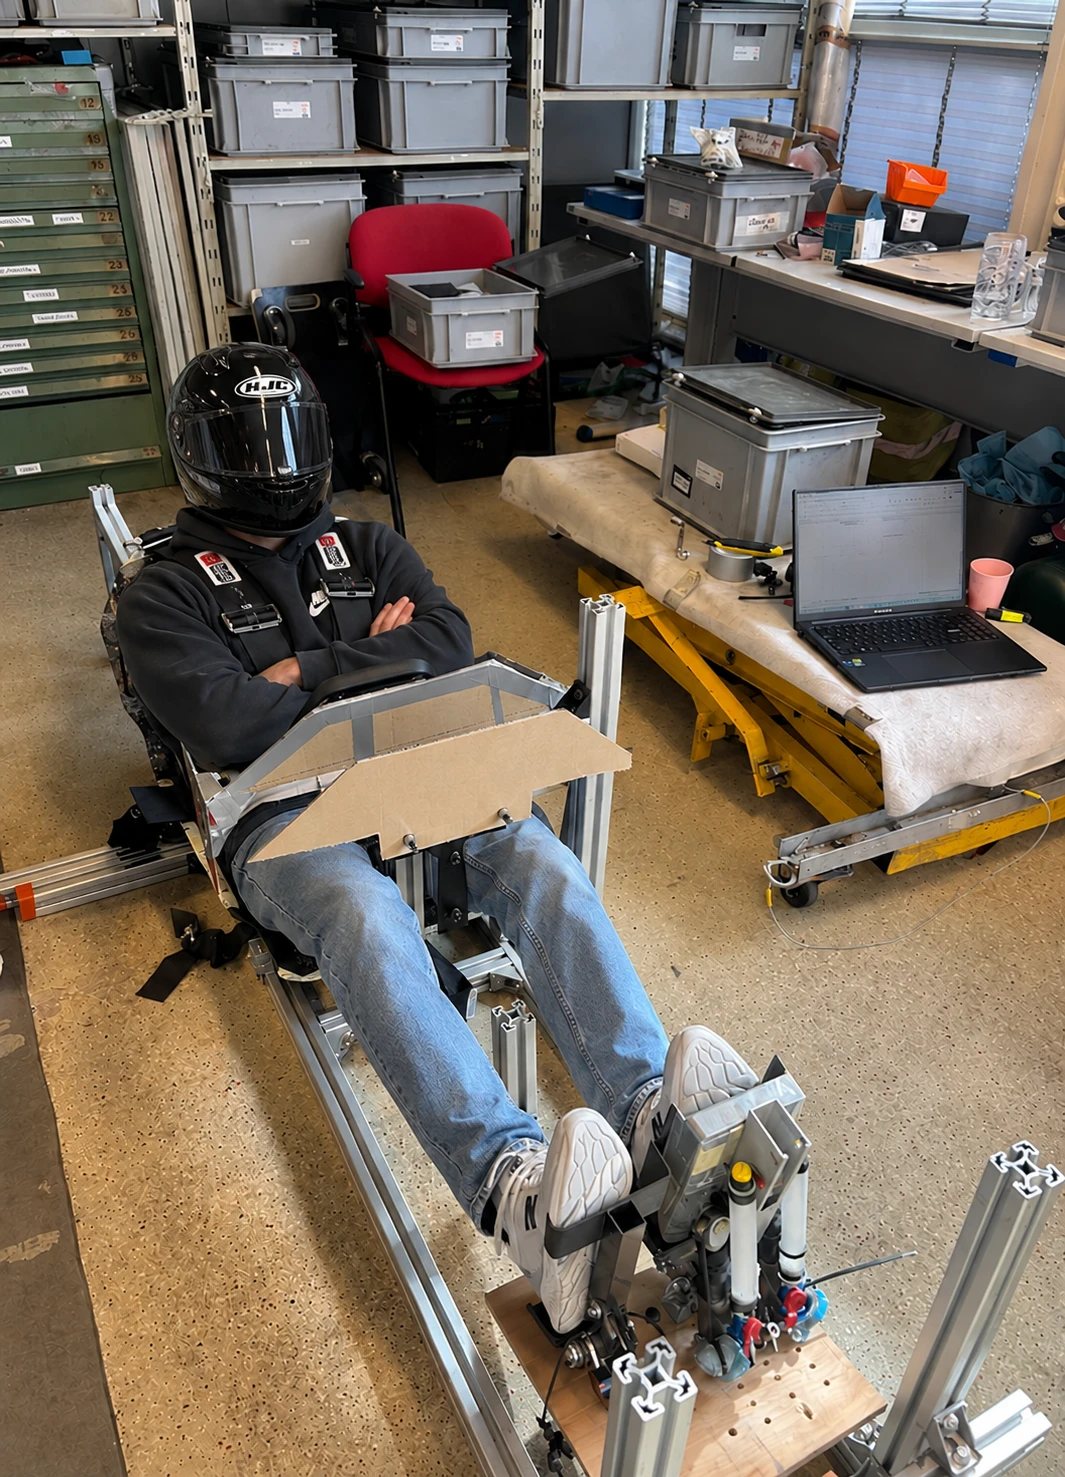
Ergonomics
Ergonomics & Driver Fitment
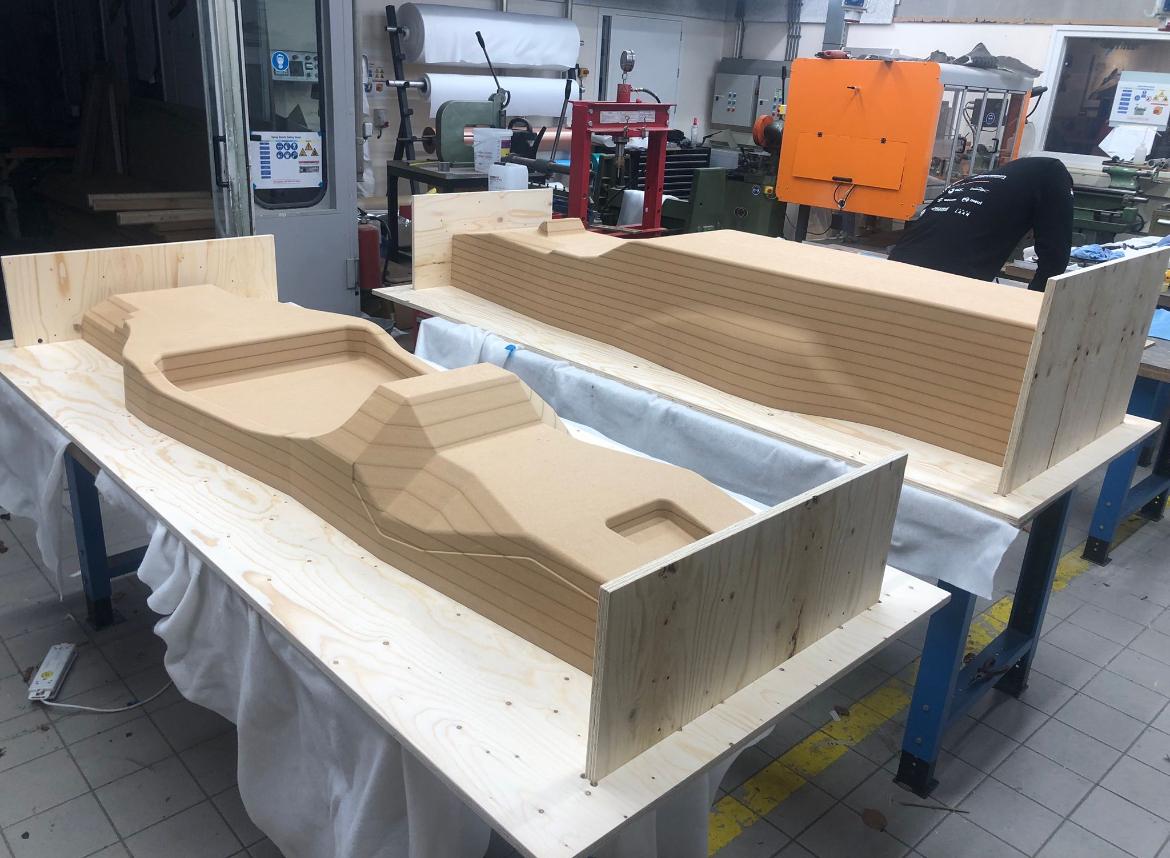
Tooling Design
CAD Tooling Design
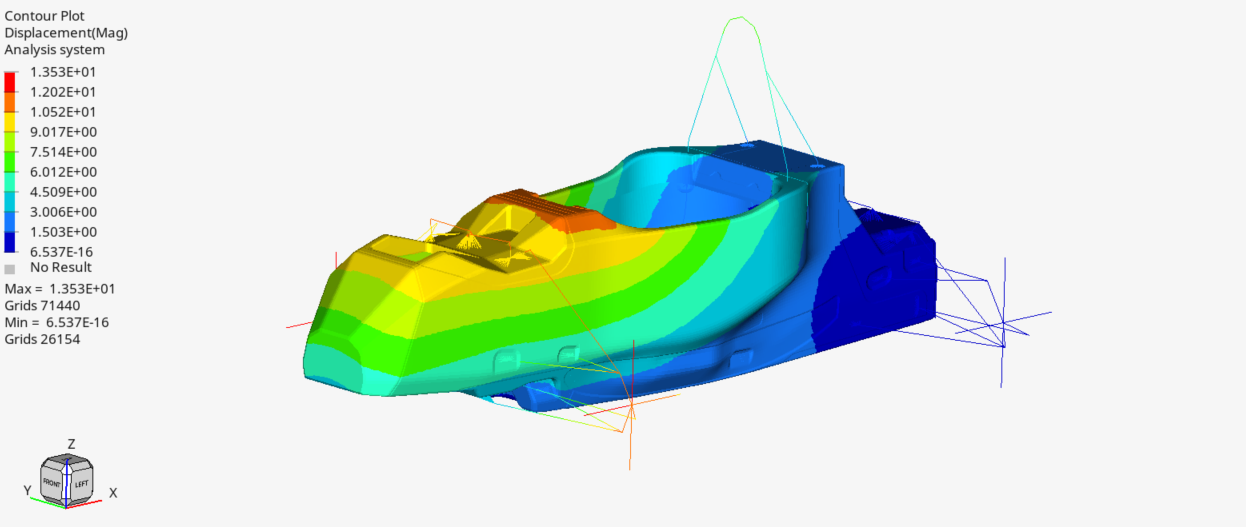
Structural Simulation
Chassis Torsional Stiffness Simulation
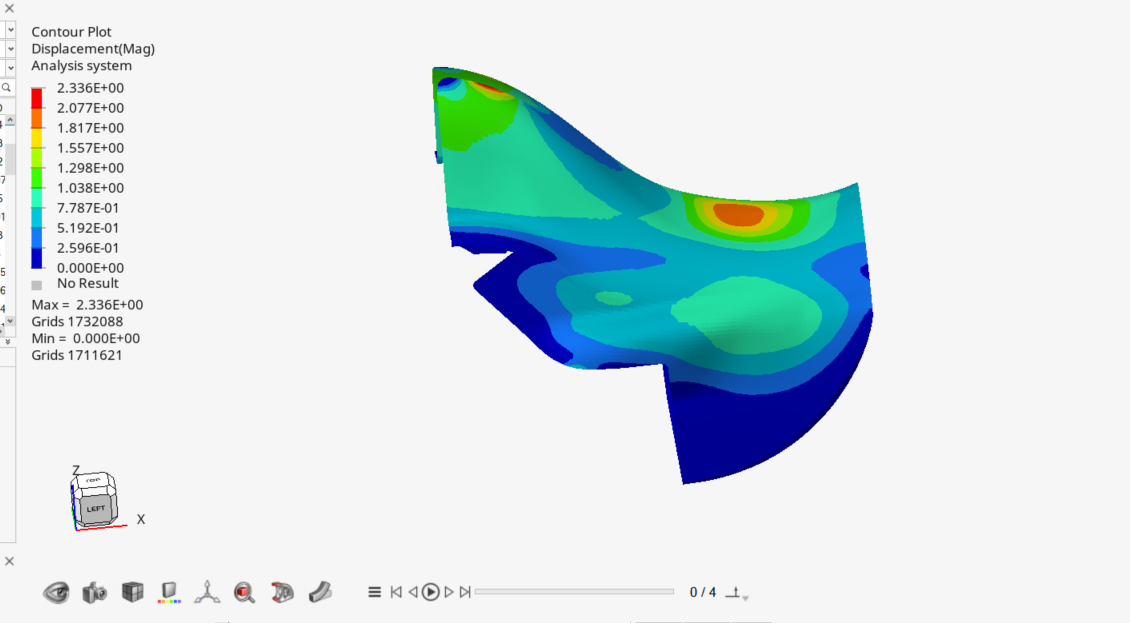
Structural Simulation
FEA Aerodynamic Devices Simulation
Manufacturing / DFM
Composite Manufacturing & Drapability Simulation
Software Engineering / AI
Nutri AI: Free Health Tracking
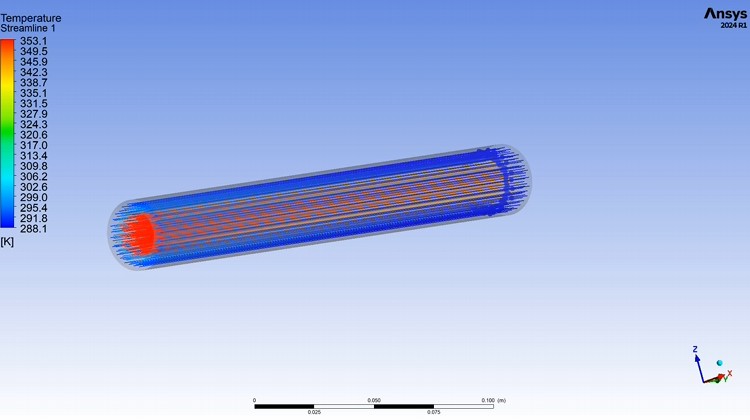
CFD / Thermofluids
Heat Exchanger CFD Model in ANSYS